
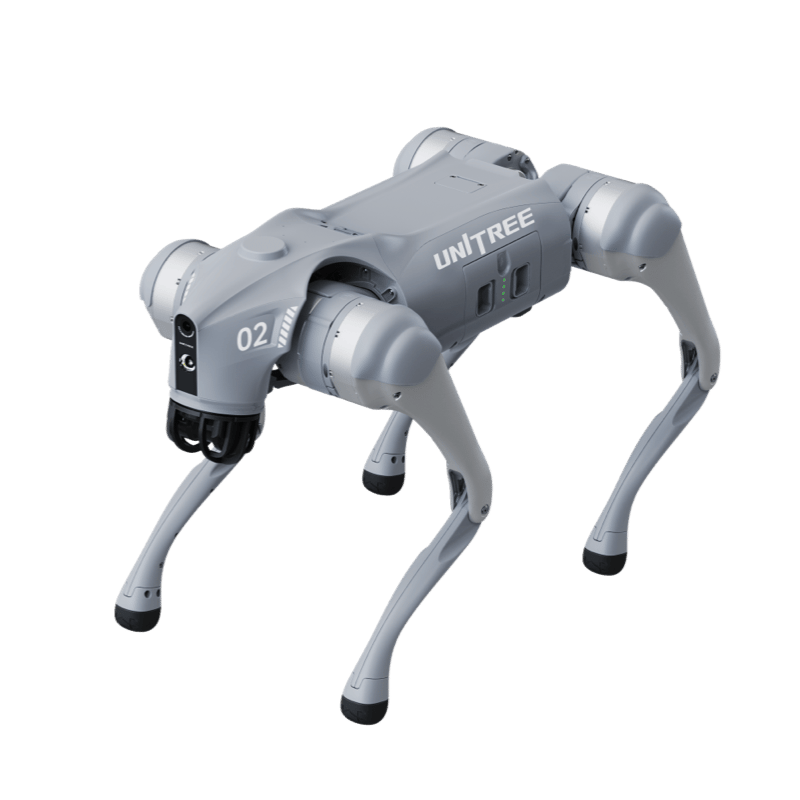
- Setup your Dog - requirements, install, connecting to your Go2, and agentic control
- Simulation - try it with no hardware via replay or MuJoCo
- Mapping & Navigation - live nav, premap recording, and relocalization
Available Blueprints
Add
--replay (recorded session) or --simulation (MuJoCo) to any of these to run without hardware.
Deep Dive
- Using navigation - send goals by viewer click, Python, or language
- Navigation stack - column-carving voxel mapping, costmap generation, A* planning
- Relocalization - record →
dimos map global --export→ replay or live deploy - Tutorial: drive the Go2 with language - the agentic stack end to end
- Visualization - Rerun, performance tuning
- Streams - RxPY streams, backpressure, quality filtering
- Blueprints - composing modules